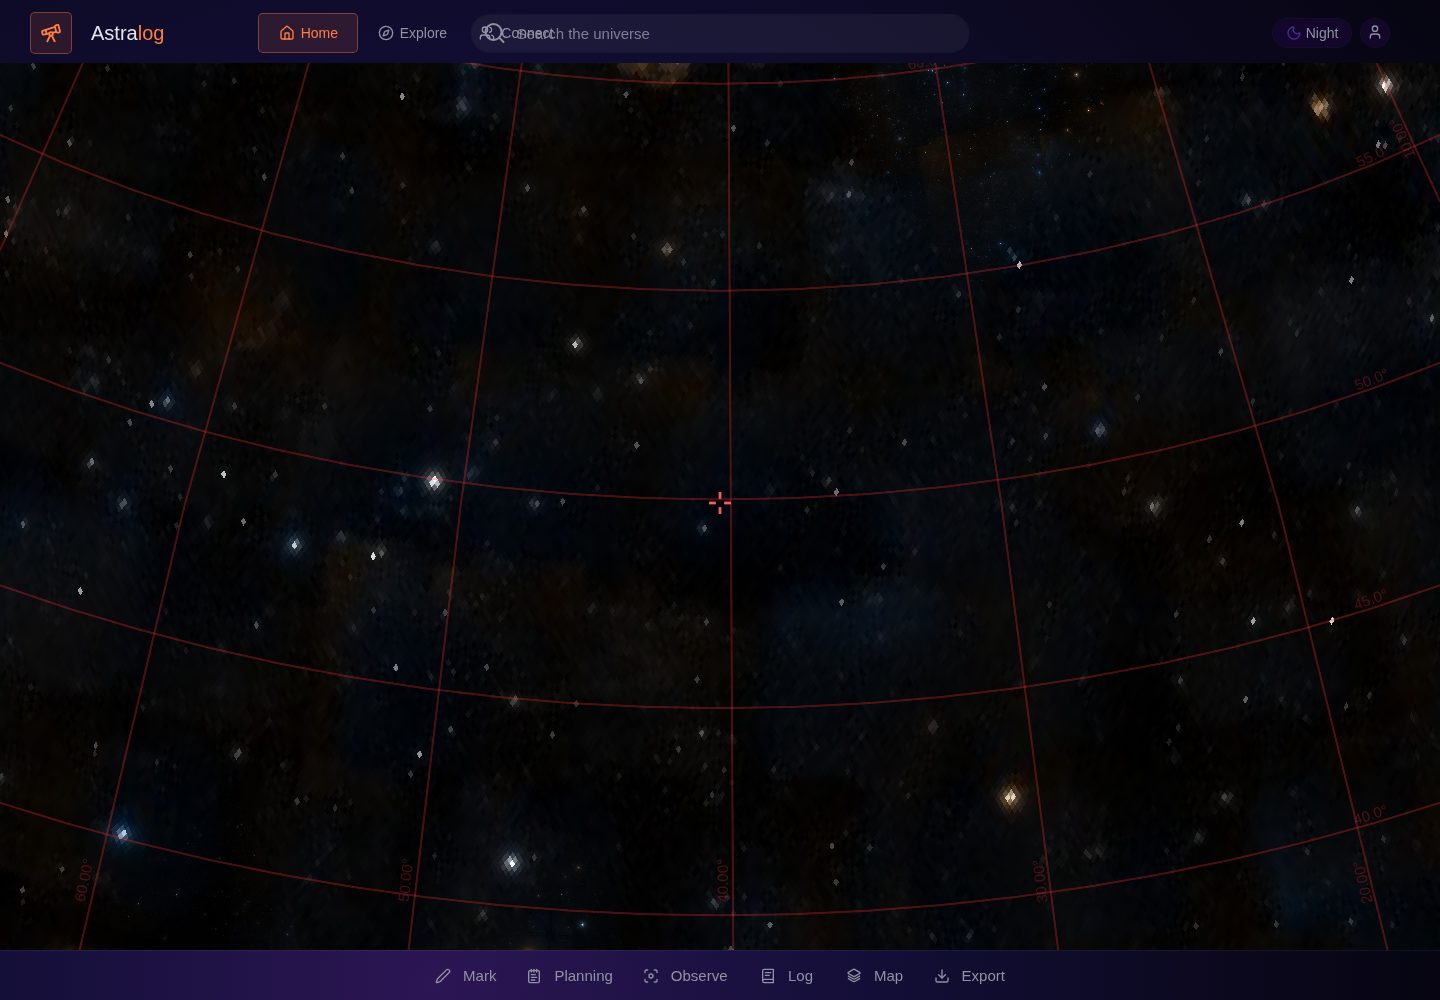
根据焦距和传感器尺寸计算视场角,结合 SIMBAD 星表的长轴、短轴和位置角估算目标投影大小,并随相机旋转更新视场叠加层
Astro作品集
LightFromAfar — Astro 作品集模板
作者 ugurrehimov-create
LightFromAfar 是一个面向天文摄影规划与记录的单页 Web 应用,提供设备感知的取景与曝光建议、Alpaca 设备控制、会话日志和本地图库。
看看你的网站会是什么样
浏览真实页面截图,比较内容排版与手机效果。点击下方缩略图切换,放大查看整页细节。
全部页面与视图 2
截图用于了解视觉与布局,交互效果请以实际项目为准。
采集于 2026-10-19查看来源
值得关注的模板亮点
从已有项目资料中,快速了解它的特点。
按安装方式给出曝光建议:三脚架提供粗略 NPF 规则估算,星野赤道仪和赤道仪视为跟踪设置,经纬仪提示场旋可能限制长曝光
Session Log 支持搜索、编辑、删除会话,记录视宁度、透明度、云量和导星 RMS,并可导出 CSV/JSON 及导入 JSON 备份
Observe 工作区在设备可用时通过 Alpaca 控制赤道仪、相机、调焦座、滤镜轮和旋转器,支持本地拍摄序列构建与曝光执行
本地 Gallery 支持照片导入、元数据、标签、处理/拍摄备注、收藏、编辑删除和 JSON 导出,并可发布到本地 Explore 工作区
地图底栏提供 DSS2、Pan-STARRS、2MASS 和 AllWISE 等天空巡天选择,使用 Aladin Lite 巡天 ID
模板详细介绍
LightFromAfar 是一个基于浏览器运行的天文摄影工作台,README 显示其核心功能围绕成像规划、设备控制和记录展开。在取景方面,它根据焦距和传感器尺寸计算视场角,结合 SIMBAD 星表的目标长轴、短轴和位置角估算目标在画面中的投影大小,并随相机旋转更新视场叠加层;当星表缺少位置角时,只做保守的长轴检查。曝光建议会区分三脚架、星野赤道仪和经纬仪等安装方式,对三脚架提供粗略的 NPF 规则估算,对经纬仪提示场旋可能限制长曝光。
应用包含 Session Log,可搜索、编辑、删除会话,记录视宁度、透明度、云量和导星 RMS,并支持 CSV/JSON 导出与 JSON 导入合并。v25 起加入 Observe 工作区,用于在设备可用时通过 Alpaca 控制赤道仪、相机、调焦座、滤镜轮和旋转器,并提供本地拍摄序列构建与相机曝光执行。v27 增加本地 Gallery,支持照片导入、元数据、标签、处理/拍摄备注、收藏、编辑删除和 JSON 导出,发布到 Explore 的内容仅显示在本地工作区,跨用户发布仍需后端服务。
数据保存在浏览器本地存储,JSON 导出/导入是手动备份而非云同步。Service Worker 仅在受支持的 HTTP/HTTPS 源下可用,外部天空/星表服务未完全离线化。README 明确说明验证以源码级检查为主,未声称在真实浏览器或硬件上完成全部交互测试。
Astro作品集
适合你的项目吗?
适用场景
- 天文摄影前规划目标在传感器上的取景范围,并随相机旋转调整构图
- 根据赤道仪、星野赤道仪或三脚架等不同安装方式获取初步曝光时长参考
- 记录每次拍摄会话的视宁度、透明度、云量和导星 RMS,并导出备份
- 在兼容 Alpaca 设备的环境中构建拍摄序列并执行相机曝光
- 在本地整理天文照片、添加标签和备注,并导出图库数据
适合人群
- 需要结合设备参数进行取景和曝光规划的天文摄影爱好者
- 使用 Alpaca 兼容设备并希望在浏览器中控制赤道仪、相机等硬件的用户
- 希望以本地存储方式记录拍摄会话和图库、不依赖云同步的用户
上手与定制指南
结合仓库当前版本的说明,按下面的资料检查内容、配置与运行要求。
- 1
README 未提供具体安装或部署步骤,仅说明 Service Worker 需在受支持的 HTTP/HTTPS 源下运行
- 2
Observe 工作区的硬件控制需要已分配且可用的 Alpaca 设备,README 未提供设备配置细节
- 3
数据保存在浏览器本地存储,JSON 导出/导入为手动备份,不是云同步
- 4
外部天空/星表服务未完全离线化,离线能力受此限制
- 5
README 的验证以源码级检查为主,未声称在真实浏览器或硬件上完成全部交互测试
授权与来源资料
使用条件与限制
免费使用 · 保留许可声明本次收录的是公开仓库中采用 MIT 许可的免费版本;免费范围为该版本代码,不代表外部服务或第三方素材免费。
使用时需要遵守
- 允许免费使用、修改、商用和分发该版本代码。
- 分发代码副本或实质性部分时,保留原作者版权声明和完整 MIT 许可声明。
- 代码按现状提供;担保与责任限制以原许可证及适用法律为准。
额外费用与待核对事项
- 演示图片、字体、图标及其他第三方素材需按各自许可核对,不能仅凭代码的 MIT 许可判断。
- 域名、托管、数据库、支付或 AI 等外部服务可能另外收费。
- 设置、标记和会话仅保存在该设备的浏览器本地存储中;JSON 导出/导入是手动备份,不是云同步。Service Worker 仅在受支持的 HTTP/HTTPS 源下可用,外部天空/星表服务未完全离线化。
- Observe 工作区的 Alpaca 赤道仪、相机、调焦座、滤镜轮和旋转器控制仅在设备已分配且可用时生效,需要兼容的 Alpaca 硬件环境。
- 不会把模拟硬件显示为已连接;设备能力与状态以显式消息呈现。
- 导星相机分配为可选;Alpaca 相机数据本身不提供导星 RMS,导星状态仅为基础设施。
- 发布到 Explore 的图库内容仅显示在本地工作区,真正的跨用户发布仍需未来的后端/账户服务。
- 图库为本地图库,图片经缩放压缩后存入浏览器存储,不是云备份。
- README 未声称在本环境中对所有浏览器交互进行了实时测试。
- 未声称在真实相机/调焦座/滤镜轮/旋转器硬件上完成测试,需兼容的 Alpaca 设备。
- 未声称在兼容 Alpaca 环境之外完成实时硬件/浏览器交互测试。
- 验证仅覆盖源码 JavaScript 语法、重复 ID 和 ZIP 完整性,未声称进行实时浏览器/硬件测试。
- 星表尺寸可能遗漏暗淡外围结构,拟合估计仅为规划辅助,不保证最终成像构图。
- 星野赤道仪和赤道仪被视为跟踪设置,实际曝光上限仍取决于对极轴、导星和赤道仪性能。
- 经纬仪虽被视为可跟踪,但应用明确警告场旋可能限制较长曝光。
查看原文依据
Permission is hereby granted, free of charge
许可证原文
Settings, marks, and sessions remain in browser local storage on that device. JSON export/import is a manual backup, not cloud sync. The service worker is available only when served from a supported HTTP/HTTPS origin. External sky/catalogue services are not made fully offline by this version.
README 原文
- Added Observe workspace for real Alpaca mount/camera/focuser/filter-wheel/rotator control when assigned and available.
README 原文
- Added explicit device capability/status messaging; no simulated hardware is shown as connected.
README 原文
- Added optional guide-camera assignment and a guiding-status foundation; AstraLog explicitly reports that Alpaca camera data alone does not provide guiding RMS.
README 原文
- Published Gallery items are shown in the local Explore workspace; real cross-user publishing still requires the future backend/account service.
README 原文
- Images are resized/compressed for browser storage. This is a local gallery, not cloud backup.
README 原文
No claim is made that every browser interaction was tested live in this environment.
README 原文
Validation note: source-level checks cover syntax, duplicate IDs and archive integrity. Real camera/focuser/filter/rotator hardware testing is not claimed without compatible Alpaca devices.
README 原文
Validation: JavaScript syntax check, duplicate HTML ID check, required-handler/static-reference checks, and ZIP integrity. Live hardware/browser interaction is not claimed without a compatible Alpaca setup.
README 原文
- Validation: source JavaScript syntax, duplicate IDs, and ZIP integrity checked; no live browser/hardware test claimed.
README 原文
- The text notes that catalogue sizes can omit faint outer structures; the fit estimate is a planning aid, not a guarantee of the final image composition.
README 原文
- Star trackers and equatorial mounts are treated as tracking setups; actual limits still depend on alignment, guiding, and mount performance.
README 原文
https://github.com/ugurrehimov-create/LightFromAfar/blob/main/LICENSEhttps://github.com/ugurrehimov-create/LightFromAfar/blob/main/README.md- Alt-azimuth mounts are treated as tracking-capable, but the app explicitly warns that field rotation may limit longer exposures.
README 原文
DeepSeek 根据仓库许可证和 README 整理 ·2026-10-19。结果仅覆盖已读取资料,依赖、图片、字体及后续条款变更以各自原文为准。
项目核对记录与介绍依据
模板资料
- 来源平台
- GitHub
- 资料与维护参考分
- 资料较完整 · 80 / 100
- 技术栈
- Astro
- 网站类型
- 作品集
这个分数如何计算
本站按许可资料(最高30分)、演示链接(12分)、预览图(10分)、Star数(15分)、记录的维护时间(15分)、描述完整度(8分)、功能记录(5分)和分类资料(5分)计算。它不是代码、安全或性能测试,也不是 Google 评分;有链接不代表已实测可用。
这个项目需要核对什么
- 记录的仓库更新时间
- 2026-10-18
- 截图检查日期
- 2026-10-19
已收录演示链接。请用你的内容与屏幕尺寸检查;有演示不代表表单、认证或支付已经可用。
目录记录的主要技术栈是 Astro。请通过依赖清单和锁文件核对实际版本与托管要求。这些说明基于收录资料,不代表代码审计或部署实测。
查看具体选型方法 →介绍的制作与核对状态
介绍由 AI 辅助整理目录与仓库资料。仓库作者不等于这篇介绍的审核者。
审核声明: codex-user-requested-batch-review-20261021 · 2026-10-21
查看当时使用的来源资料
SHA-256: 411aad7f6038fe56f016ddb8b129604f8adac2d8283053cbe8be4b60c88088f5
2026-10-19T02:01:42.423Z
来源文件 / 仓库# VesperNode v27 — Equipment-Aware Framing This version builds on v21's Session Log improvements and improves how the saved imaging setup informs framing and exposure guidance. ## Equipment-aware framing - Uses focal length and sensor width/height to calculate the actual angular field of view, plus focal ratio and image scale when the relevant values are supplied. - The target details view uses SIMBAD's catalogued major axis, minor axis, and position angle (when available) to estimate the target's projected size at the selected camera rotation. - Framing advice checks both frame dimensions and uses a 10% margin when the catalogued position angle is available. When it is not available, it reports a conservative major-axis check instead of pretending to know the orientation. - Changing camera rotation updates the framing estimate, and the FOV overlay uses that rotation. The overlay requires focal length and both sensor dimensions. - The text notes that catalogue sizes can omit faint outer structures; the fit estimate is a planning aid, not a guarantee of the final image composition. ## Mount-aware exposure advice - Tripod-only setups can receive a rough NPF-rule untracked exposure estimate when focal length, aperture, and pixel size are provided. - Star trackers and equatorial mounts are treated as tracking setups; actual limits still depend on alignment, guiding, and mount performance. - Alt-azimuth mounts are treated as tracking-capable, but the app explicitly warns that field rotation may limit longer exposures. ## Session Log (from v21) - Search, edit, and delete saved sessions. - Record seeing, transparency, cloud cover, and guiding RMS. - Export CSV and JSON backups; import JSON backups with record validation and ID-based merging. ## Data and offline note Settings, marks, and sessions remain in browser local storage on that device. JSON export/import is a manual backup, not cloud sync. The service worker is available only when served from a supported HTTP/HTTPS origin. External sky/catalogue services are not made fully offline by this version. ## Validation performed - JavaScript syntax check (`node --check` on extracted inline script). - Duplicate HTML ID check. - ZIP archive integrity test. - Static checks for mount-aware guidance, camera-rotation refresh, and SIMBAD size/position-angle fields. No claim is made that every browser interaction was tested live in this environment. ## v25 — Imaging control foundation - Added Observe workspace for real Alpaca mount/camera/focuser/filter-wheel/rotator control when assigned and available. - Added persistent local capture-sequence builder and camera exposure execution. - Added explicit device capability/status messaging; no simulated hardware is shown as connected. - Redesigned Tonight's imaging session marked-target cards so content uses the full card width instead of inheriting the generic event two-column layout. - Fixed Marks panel action layout so Details and Go to belong to each mark instead of appearing as detached controls. - Camera rotation state remains persisted per target. - Service worker cache bumped to v25. Validation note: source-level checks cover syntax, duplicate IDs and archive integrity. Real camera/focuser/filter/rotator hardware testing is not claimed without compatible Alpaca devices. ## v26 — Bug fixes, Planning/Log workflow, and capture foundations - Moved Tonight's Imaging Session into Session Log so marked targets and planned events are together with one-click Log session actions. - Planning events added to the plan now appear in the Log as separate planned items, with Log session and Remove actions. - Fixed the Mark → imaging workflow persistence bug and kept target camera rotation persisted per mark ID/coordinates. - Clicking empty map space now closes an open mark popup; mark hit tolerance was increased for easier selection. - Deleting a marked target now clears its FOV overlay and closes stale target state. - Bottom-bar controls are centered; sidebar controls are slightly larger; Observe uses a matching line icon. - Map bottom-bar control now returns to the map/Home workspace instead of silently cycling survey names. - Observe mount Abort Slew now checks whether the mount is actually slewing before sending the command. - Added optional guide-camera assignment and a guiding-status foundation; AstraLog explicitly reports that Alpaca camera data alone does not provide guiding RMS. - Added persistent last-capture summary after a completed capture sequence and a one-click Log capture action. - Capture summary carries target, frame count, integration time, completion time, and active optical train into Session Log. - Service worker cache bumped to v26. Validation: JavaScript syntax check, duplicate HTML ID check, required-handler/static-reference checks, and ZIP integrity. Live hardware/browser interaction is not claimed without a compatible Alpaca setup. ## v27 — Map Surveys, Community Layout, and Gallery Foundation - Map bottom-bar control now opens an explicit sky-survey chooser instead of cycling surveys invisibly. - Added DSS2 color/red/blue, Pan-STARRS color, 2MASS, and AllWISE survey choices using Aladin Lite survey IDs. - Explore and Connect hide the bottom bar and use the full available vertical workspace. - Sidebar active-state highlighting now applies to working Settings, Gallery, Marks, HZ Calculator, and About windows. - Replaced the Observe bottom-bar icon with Lucide Focus for consistency with the existing icon family. - Added local Gallery with photo import, metadata, tags, processing/capture notes, favorites, delete/edit, local JSON export, and Post to Explore. - Published Gallery items are shown in the local Explore workspace; real cross-user publishing still requires the future backend/account service. - Images are resized/compressed for browser storage. This is a local gallery, not cloud backup. - Validation: source JavaScript syntax, duplicate IDs, and ZIP integrity checked; no live browser/hardware test claimed.
看看同类模板
对比同技术栈与用途的模板,找到更适合的视觉与内容结构。
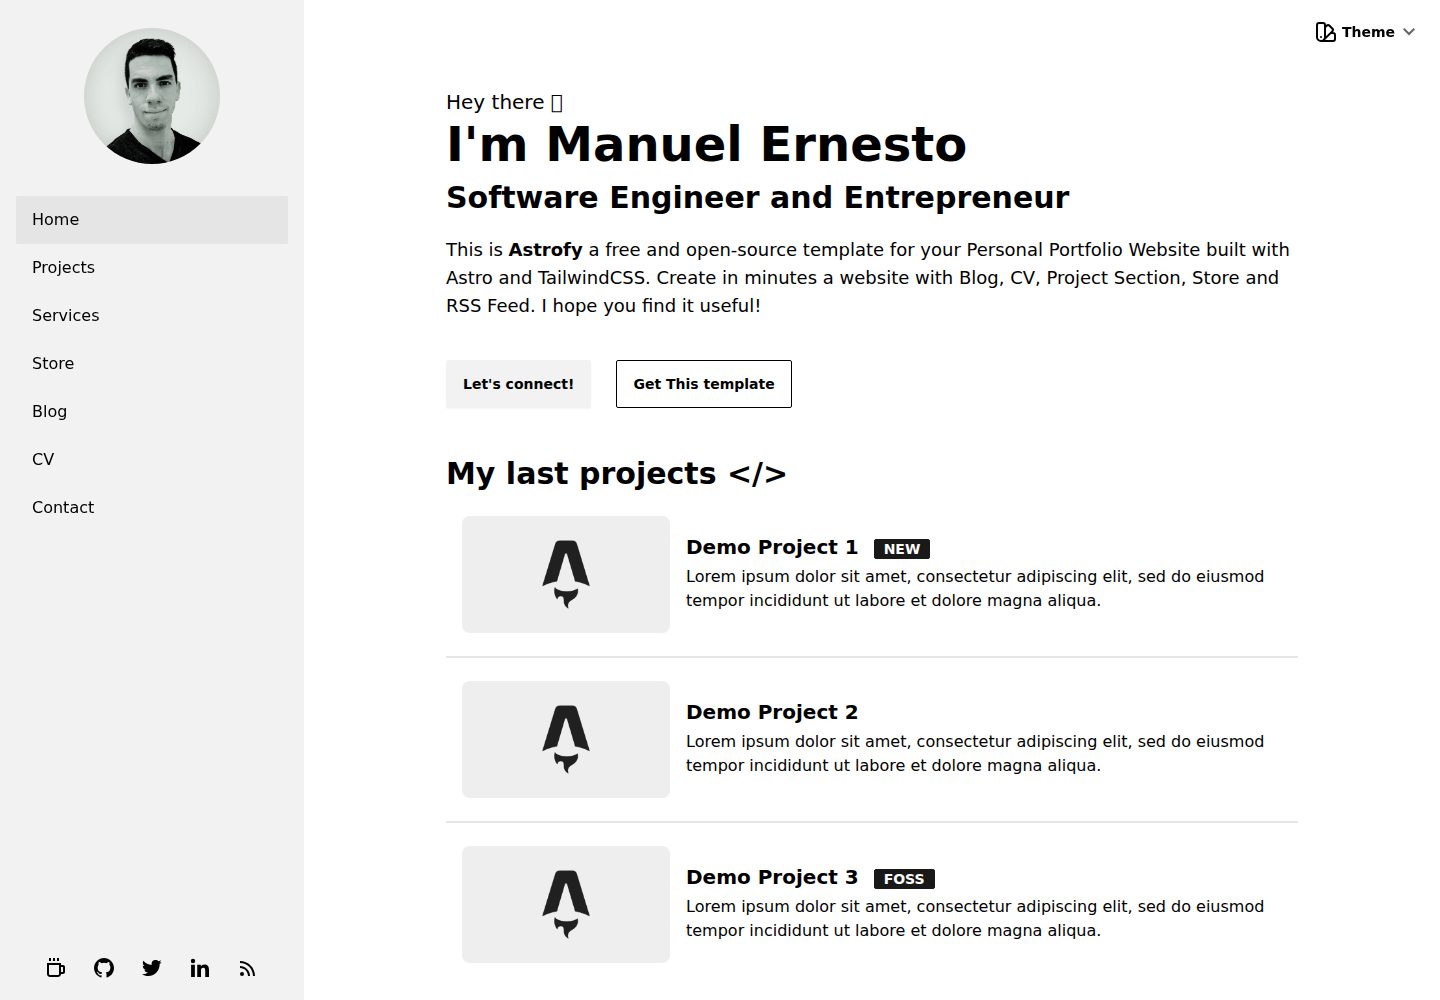
astrofy
Astrofy is a free and open-source template for your Personal Portfolio Website built with Astro and TailwindCS…
Astro · 作品集
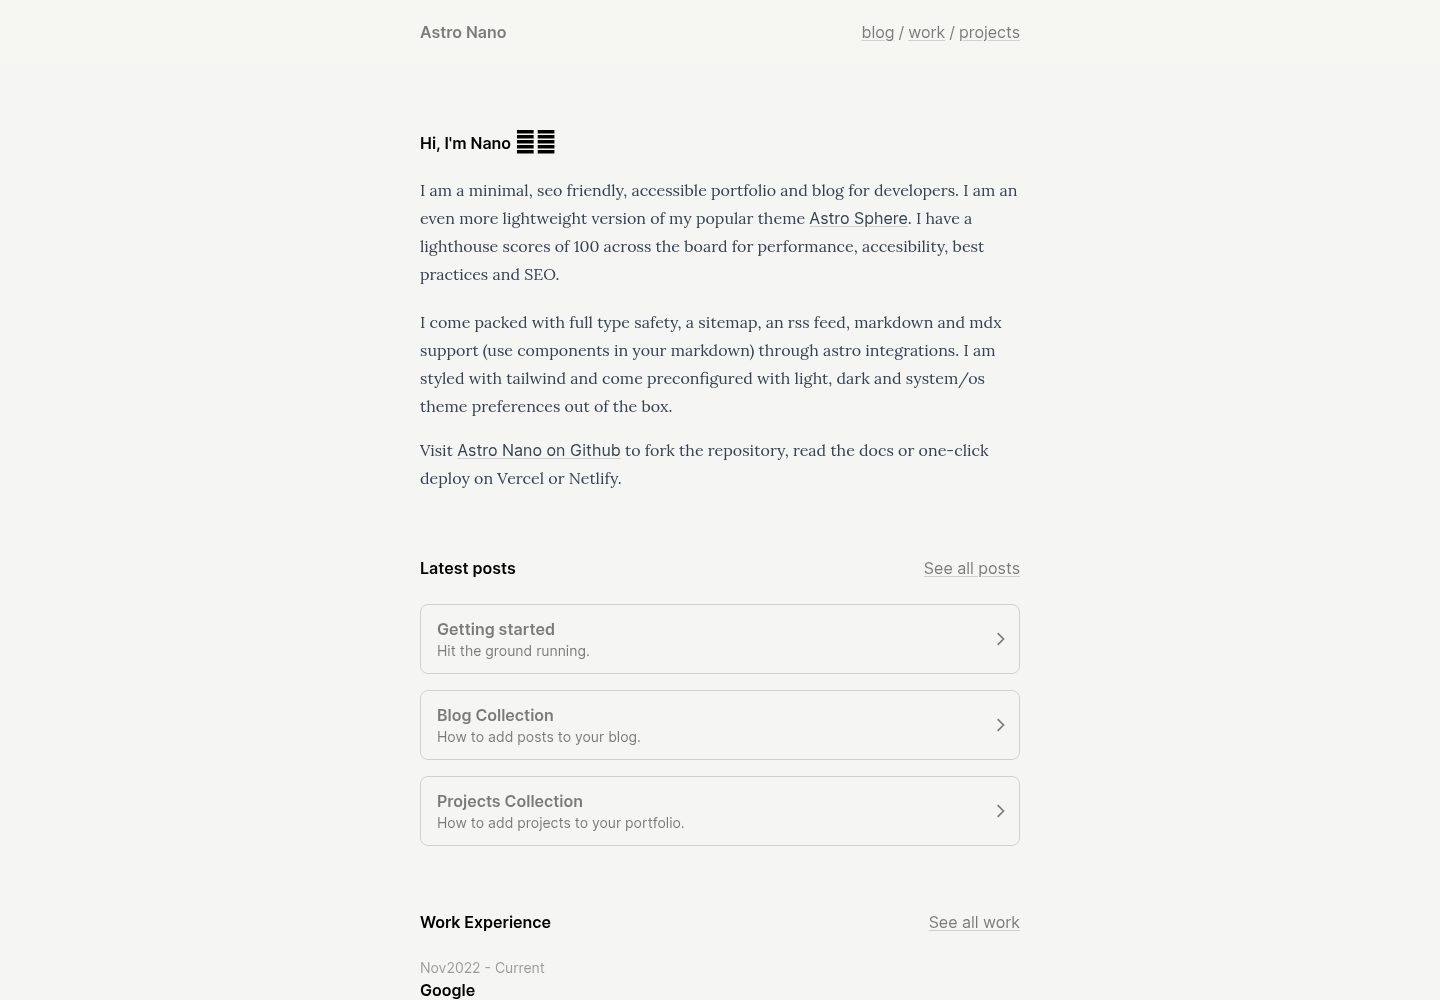
astro-nano
Astro Nano is a static, minimalist, lightweight, lightning fast portfolio and blog.
Astro · 作品集
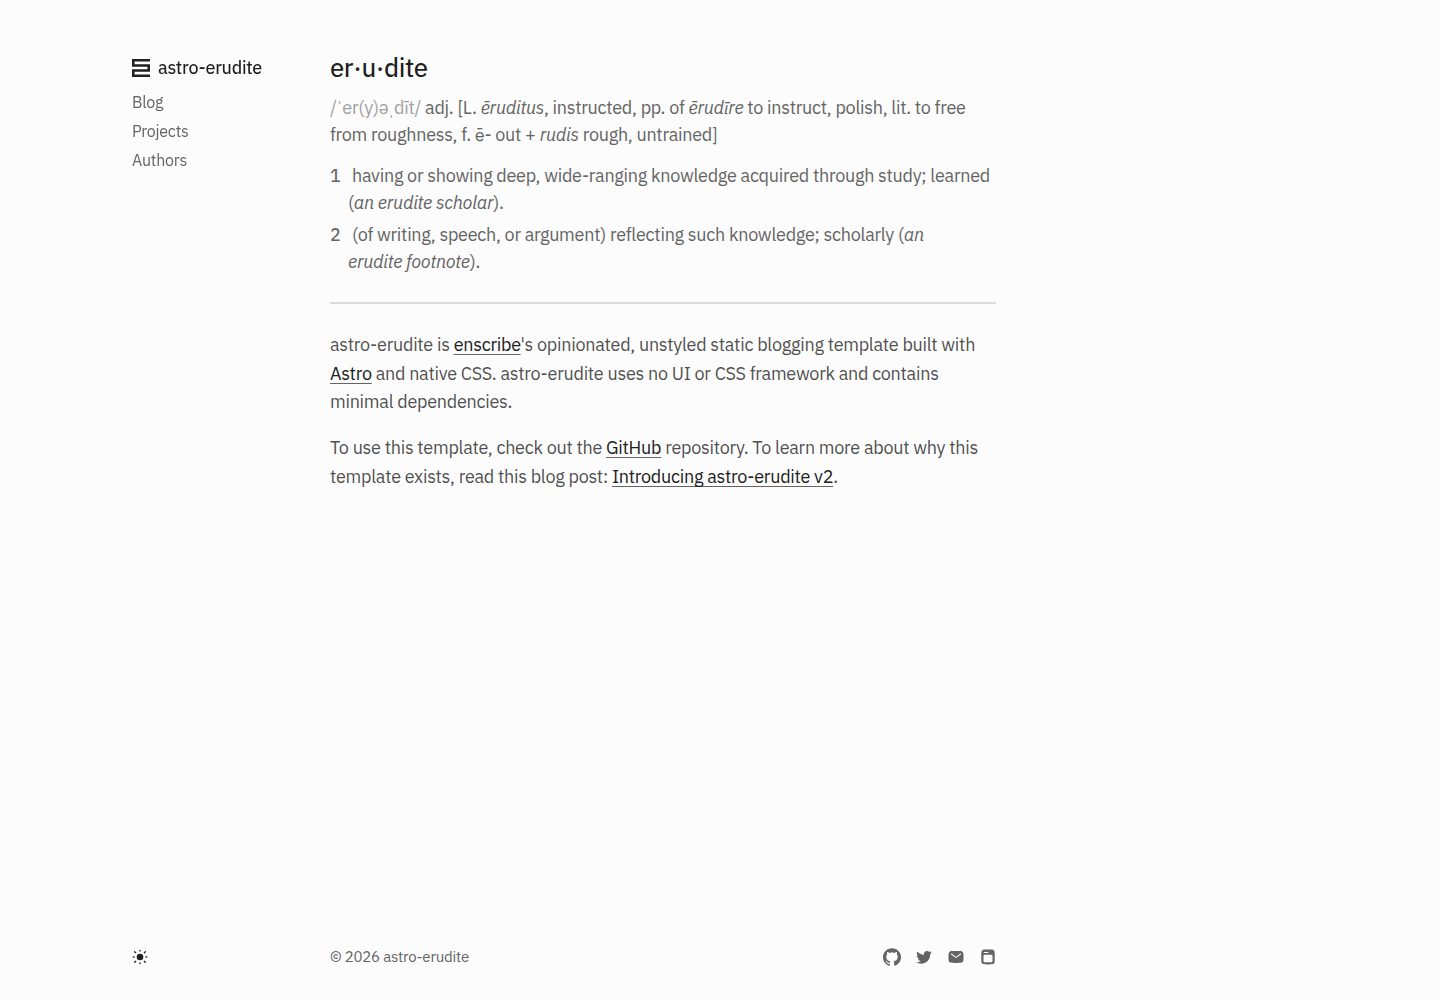
astro-erudite
An opinionated, unstyled static blogging template built with Astro and native CSS.
Astro · 作品集
astro-sphere
Astro Sphere is a static, minimalist, lightweight, lightning fast portfolio and blog.
Astro · 作品集
astro-micro
Blog theme for Astro with search and comments built-in. Zero frameworks.
Astro · 作品集
astro-aria
A personal blog, portfolio, or blog template
Astro · 作品集